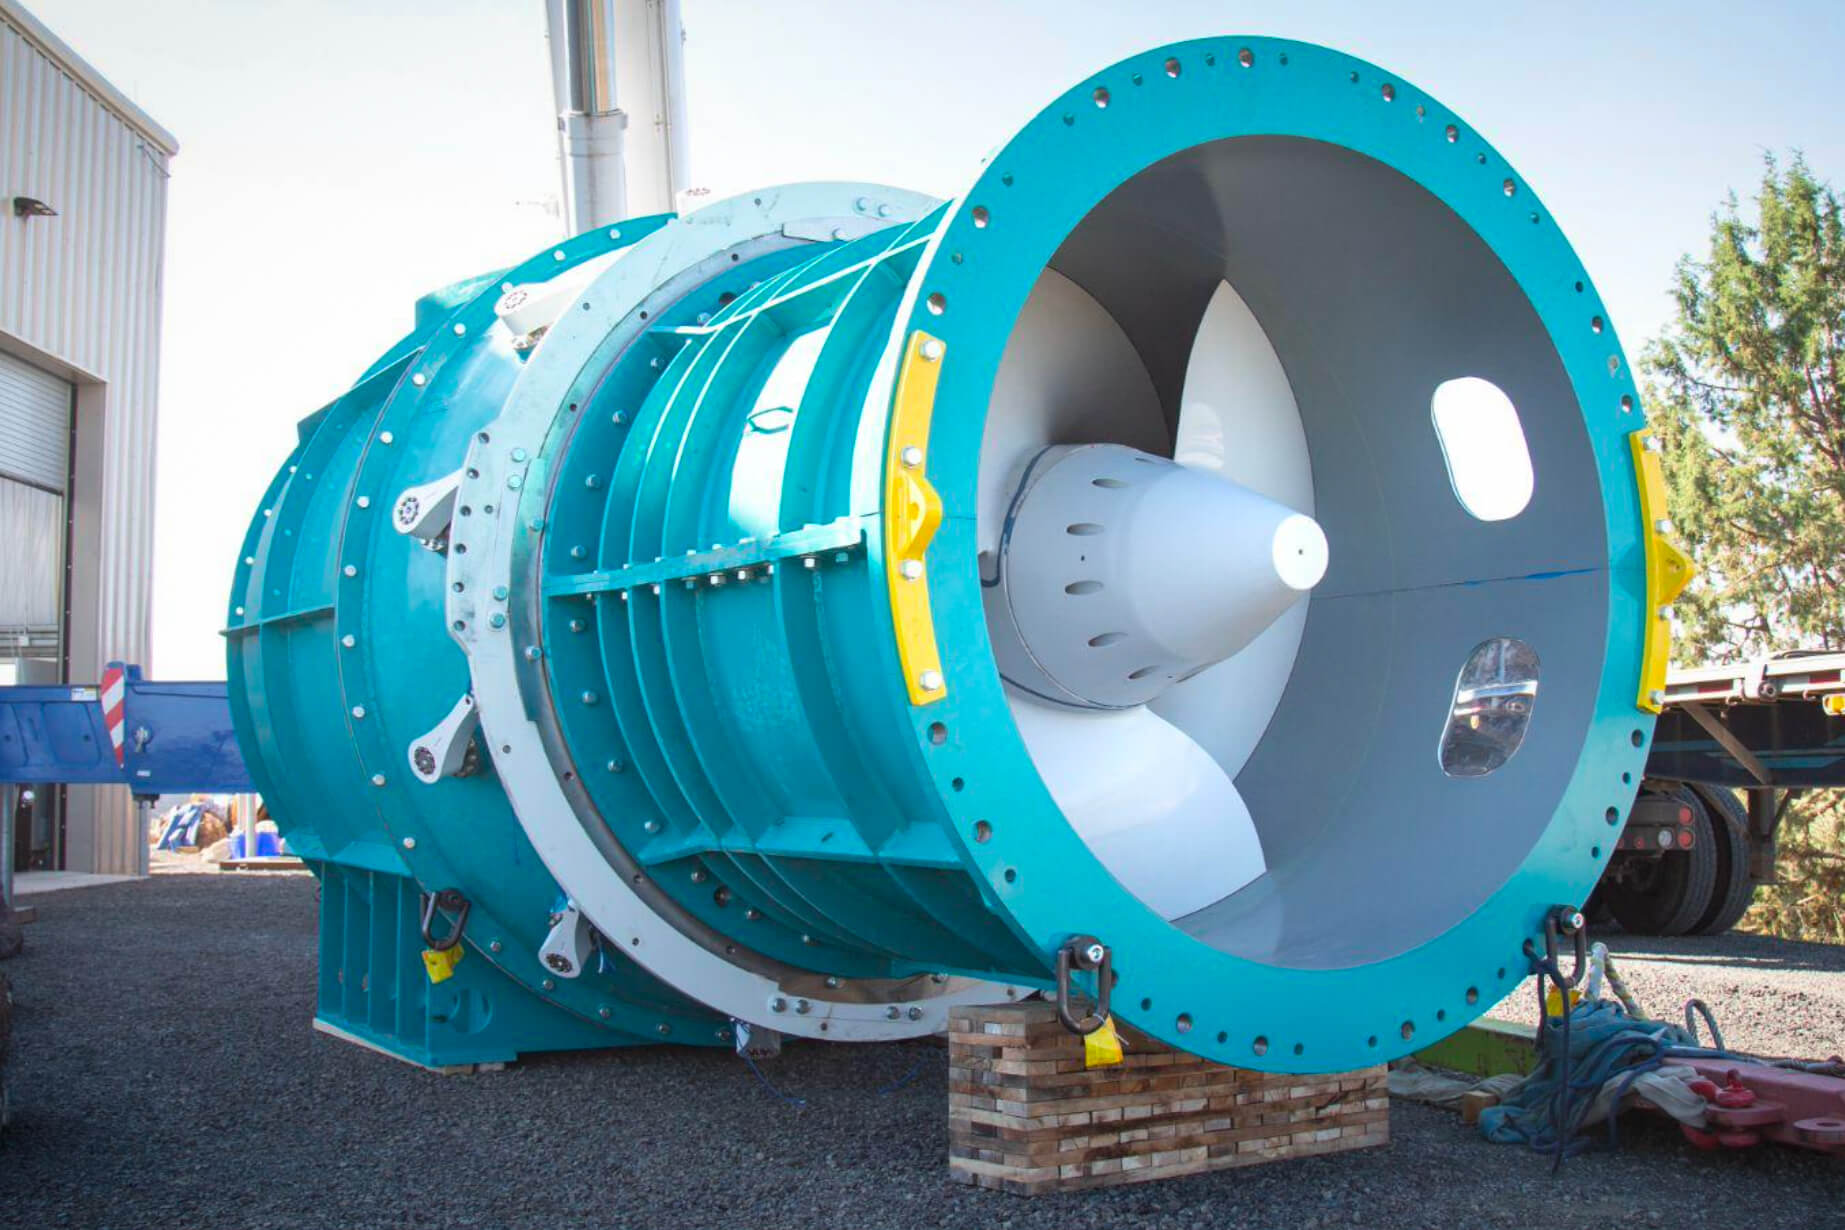
The Electromechanical Challenge in Legacy Run-of-the-River Turbines
Hydroelectric power stations constructed between the late 1960s and 1990s across Northern Pakistan and Khyber Pakhtunkhwa frequently depend on mechanical-hydraulic or legacy analog governors. While the mechanical runner, scroll casing, and guide-vane linkages often remain structurally sound after decades of continuous operation, the legacy control electronics suffer from progressive drift, uncalibrated pilot valve hysteresis, and non-existent integration with modern national grid management protocols.
At Ghousia Energy Solutions, our electromechanical field teams specialize in non-invasive retrofitting: retaining prime mechanical assets while entirely replacing obsolete analog control racks with high-speed programmable automation controllers, closed-loop electro-hydraulic servo interfaces, and optical bus SCADA architectures.
Key Engineering Principle: Speed Droop & Primary Frequency Response
To operate harmoniously within an interconnected electrical grid, hydro turbines cannot run under pure isochronous control. Digital governors must implement a precise adjustable speed droop (typically 3% to 5%) ensuring proportional load sharing during sudden grid frequency deviations across 49.5 Hz to 50.5 Hz boundaries.
Digital Governor Architecture: Step-by-Step Upgrades
The transition from analog mechanical linkages to closed-loop digital control involves four integrated subsystems:
- Non-Contact Optical & Magnetic Speed Pickups: Redundant dual magnetic pick-up units (MPUs) mounted over the turbine shaft teeth deliver pulse-train telemetry to high-speed counter modules, eliminating analog tachometer drift.
- Electro-Hydraulic Actuator Interface: Replacing pilot valves with proportional servo valves featuring LVDT (Linear Variable Differential Transformer) feedback loops ensures guide-vane positioning accuracy within ±0.1% stroke.
- Dual-Redundant Programmable Logic Controllers: Industrial PLCs running deterministic cyclic tasks (10ms scan cycle) process speed reference, frequency error, power feedback, and head measurement simultaneously.
- Station SCADA Bus: Synchronizing local controller memory over Modbus TCP/IP and IEC 60870-5-104 directly into station master control rooms and regional load dispatch desks.
Comparative Specifications: Legacy vs. Upgraded Control Architecture
| System Parameter | Legacy Mechanical/Analog System | Modernized Digital PLC & SCADA System |
|---|---|---|
| Speed Sensing Mechanism | Flyball / Analog Tachometer | Dual Redundant Digital MPU / Optical Encoders |
| Positioning Precision | ±1.5% to ±3.0% of guide-vane stroke | ±0.08% via LVDT Closed-Loop Feedback |
| Deadband / Sensitivity | > 0.05 Hz | < 0.005 Hz (Micro-frequency regulation) |
| Telemetry & Event Logging | Manual circular chart paper | 1ms Sequence of Events (SOE) / Cloud Telemetry |
| Grid Protocol Compliance | None / Hardwired relay interlocks | IEC 60870-5-104 / IEC 61850 / Modbus TCP |
Field Validation: The Chianwali Rehabilitation Experience
During our electromechanical rehabilitation work on Unit-01 and Unit-02 at the Chianwali Hydropower Project in 2024, our engineers identified severe governor hunting and pilot valve oscillation that caused recurrent trip events during synchronizing maneuvers. By replacing faulty analog cards with a unified PLC architecture and fine-tuning the proportional-integral-derivative (PID) gains for both opening and closing stroke regimes, turbine settling time dropped by 64%, eliminating hunting across the full operational head envelope.
// Representative PID Governor Frequency Regulation Algorithm
IF GridConnected THEN
    FreqError = TargetFrequency - ActualFrequency;
    SpeedReference = NominalSpeed * (1.0 - (DroopSetting * (ActivePower / RatedPower)));
    PID_Output = PID_Compute(SetPoint := SpeedReference, ProcessVar := ActualSpeed, Kp := 4.2, Ti := 2.8, Td := 0.15);
    GuideVaneCommand = LIMIT(PID_Output, MinOpening, MaxOpening);
END_IF;
Conclusion & Future Outlook
Electromechanical modernization delivers a powerful return on investment for asset owners: generating up to 8% higher annual energy yield from the identical hydrological resource, drastically reducing mechanical wear on servomotors, and guaranteeing faultless compliance with modern power grid dispatch codes.